Local action. Shared learning.
Tezjn is building physical AI for skilled work in the infrastructure that already exists, from mobile manipulators and robotic hands in semiconductor fabs and warehouses to robotics in space. Robots have to act where the work is, without waiting on a remote connection, yet every new task and every robot body still needs its own data, training and validation. We are building the learning that lets each robot act on its own, and lets all of them get better together.
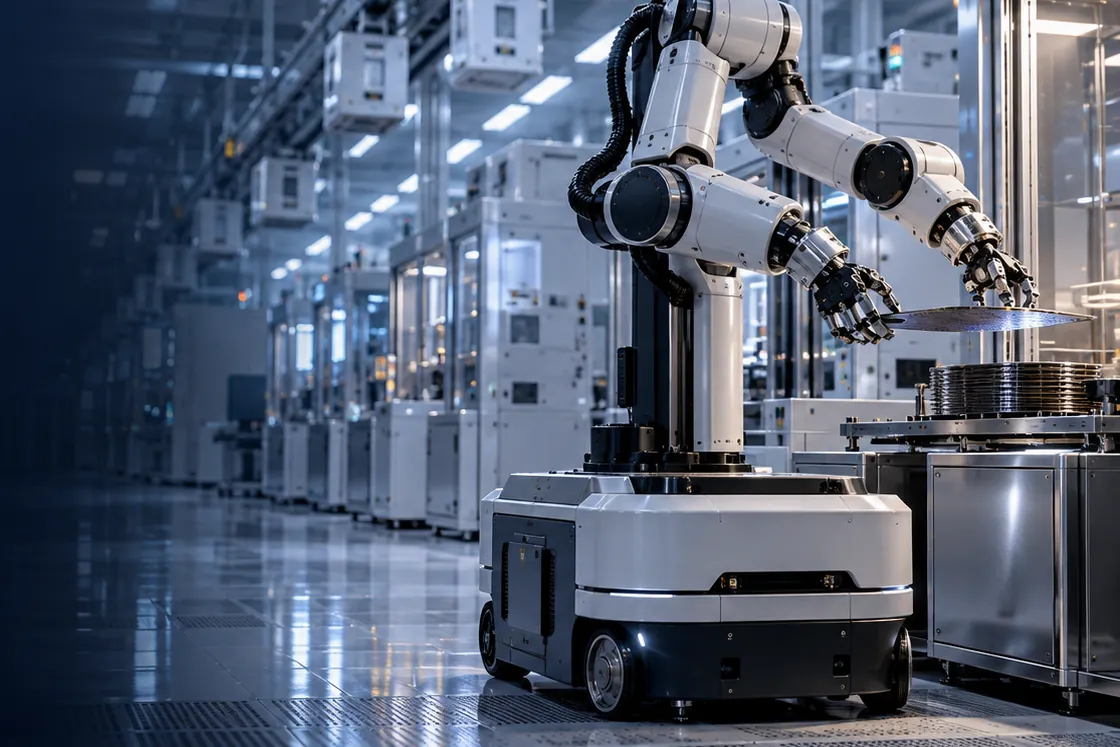
Skilled work.Existing infrastructure.
Demo of ongoing work.
Sample of a model we've developed, all in simulation.
Robots building robots.
In simulation, a robot arm assembles an SO-101 robot arm, one stage at a time.
Super lightweight models.
Robot hands.14 million parameters.
The policy is small enough to run live in a web browser. 50 times a second it moves both wrists and 40 finger joints to pick the object up, carry it and set it down; the clips show the hand doing the work.
Human hand motion: HO-Cap (Wang et al., 2024), CC BY 4.0.
Start with one workflow.
or write to hello@tezjn.com